
How Robotic Data Annotation Supports Bimanual Manipulation Tasks
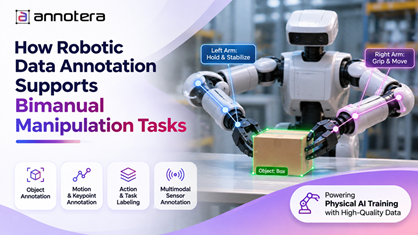
Robots are evolving beyond performing isolated movements to executing complex tasks that require coordination between two arms. From assembling electronic components and handling fragile objects to packaging products and performing warehouse operations, bimanual manipulation is becoming an essential capability in modern robotics. However, teaching robots to coordinate both arms accurately requires more than sophisticated hardware and advanced algorithms. It depends on high-quality, consistently labeled training data.
This is where robotic data annotation services play a critical role. By transforming raw sensor recordings, visual observations, and human demonstrations into structured datasets, annotation enables robots to understand object relationships, coordinate movements, and perform synchronized actions. As Physical AI advances, accurate annotation is becoming a foundation for developing robots that can interact with dynamic real-world environments.
What Is Bimanual Manipulation in Robotics?
Bimanual manipulation refers to a robot's ability to use two robotic arms simultaneously or sequentially to complete a coordinated task. Unlike single-arm manipulation, which generally involves controlling one end effector, bimanual operations require managing interactions between two arms, objects, and the surrounding environment.
Common examples include:
-
Assembly operations: Holding a component with one arm while another arm inserts, tightens, or connects another part.
-
Packaging and folding: Stabilizing packaging material with one hand while the other folds or seals it.
-
Object handling: Lifting, rotating, and repositioning large or irregularly shaped objects using both arms.
-
Warehouse operations: Grasping and transferring bulky products that require two-arm coordination.
-
Household assistance: Opening containers, folding clothes, and handling objects that require coordinated movements.
These tasks involve complex relationships between position, orientation, force, timing, and contact. Robots must understand what each arm should do, when movements should occur, and how both arms should interact without creating collisions or destabilizing objects.
Why High-Quality Data Matters for Bimanual Manipulation
Bimanual manipulation introduces several challenges for robot learning. Both arms must operate within a shared workspace while maintaining appropriate coordination and responding to changing environmental conditions.
A robot may successfully grasp an object with one arm but fail when required to stabilize it while the second arm performs another operation. Similarly, inaccurate timing or excessive force from either arm can compromise the entire task.
High-quality training datasets help address these challenges by capturing:
-
Coordinated movement patterns: How both arms move in relation to each other.
-
Object interaction: How robotic hands grasp, hold, rotate, and release objects.
-
Spatial relationships: The position and orientation of both arms relative to objects.
-
Force and contact information: How much pressure is applied during manipulation.
-
Task sequencing: The correct order and timing of actions.
Accurate annotations convert these observations into meaningful training signals, helping robotic learning models understand complex interactions rather than simply reproducing individual movements.
6 Ways Robotic Data Annotation Supports Bimanual Manipulation Tasks
1. Capturing Coordinated Two-Arm Movements
One of the biggest challenges in bimanual manipulation is ensuring that both arms work together. Each arm may perform a different action, but their movements must remain synchronized to achieve the intended outcome.
Robotic data annotation identifies individual arm trajectories, joint positions, end-effector movements, and synchronized action sequences. These annotations help distinguish between independent movements and coordinated operations.
For example, during an assembly task, one arm may hold a component steady while the other inserts a connecting part. Annotated demonstrations provide the temporal and spatial information needed to train models to reproduce this coordinated behavior.
2. Improving Object Detection and Grasping Accuracy
Successful bimanual manipulation begins with understanding the objects being handled. Robots must identify object boundaries, dimensions, orientation, grasping points, and potential contact areas.
Image annotation techniques such as bounding boxes, semantic segmentation, instance segmentation, and keypoint annotation help identify objects and their relevant features.
For example, when a robot handles a large box, one arm may grasp its left side while the other secures the right side. Annotated grasp locations and object geometry help models determine suitable contact points and maintain object stability throughout the operation.
3. Supporting Action Recognition and Task Sequencing
Bimanual operations often involve multiple dependent actions. A robot may need to grasp an object, stabilize it, rotate it, perform an operation, and release it in a specific sequence.
Action annotation helps categorize these movements into meaningful task segments. Labels such as grasp, hold, rotate, transfer, align, manipulate, and release provide structured information about what the robot is doing at different stages.
This is particularly valuable for training learning-based robotic systems that must understand task progression and select appropriate actions based on the current environment.
4. Enabling Multimodal Sensor Fusion
Visual information alone cannot always explain how a robot interacts with an object. Bimanual manipulation also depends on tactile feedback, force measurements, joint states, and spatial information.
Multimodal annotation connects different sensor streams, including:
-
RGB and depth camera recordings.
-
Joint positions and velocity measurements.
-
Force and torque sensor readings.
-
Tactile feedback and contact information.
-
End-effector poses and motion trajectories.
Synchronizing these data sources creates a more comprehensive representation of robotic interactions. This helps models understand not only what is happening visually but also how forces and movements influence task outcomes.
5. Identifying Errors and Improving Task Reliability
Even well-trained robots encounter challenges such as failed grasps, object slippage, arm collisions, and incorrect movement sequences.
Failure annotation helps identify these situations and categorize their causes. For example, an object may slip because one arm applies insufficient force, or a task may fail because both arms approach the same workspace simultaneously.
By labeling successful and unsuccessful demonstrations, robotic teams can build datasets that support error recognition, corrective actions, and more reliable manipulation strategies.
6. Supporting Learning from Human Demonstrations
Human demonstrations are valuable for teaching robots tasks that are difficult to describe through conventional programming. Teleoperation systems allow human operators to control robotic arms and demonstrate complex bimanual activities.
However, raw demonstrations need to be processed into structured training examples. Annotation captures action boundaries, arm trajectories, object interactions, grasp transitions, and task outcomes.
These datasets can support imitation learning, behavior cloning, and other learning approaches used in Physical AI training. Consistent annotation also helps models learn from diverse demonstrations performed under different environmental conditions.
The Role of Annotation Quality in Scaling Bimanual Robotics
As bimanual robotic systems move from controlled laboratory environments into real-world applications, dataset quality becomes increasingly important.
Inconsistent labels, missing timestamps, incorrect object boundaries, and poorly synchronized sensor streams can introduce noise into training datasets. Such problems may affect model performance and make it difficult to reproduce complex manipulation behaviors.
Robotics teams should prioritize:
-
Standardized annotation guidelines for both robotic arms.
-
Accurate temporal synchronization across sensor streams.
-
Consistent object, action, and contact labeling.
-
Quality assurance through multi-level annotation reviews.
-
Diverse datasets covering different objects, environments, and task variations.
Professional robotic data annotation services help organizations establish these processes while improving dataset consistency, scalability, and usability.
How Annotera Supports Advanced Bimanual Robotics
At Annotera, we understand that intelligent robotic manipulation requires more than collecting large volumes of raw data. It requires accurately structured information that helps machines interpret actions, interactions, and environmental changes.
Our data annotation capabilities support robotics teams working with image, video, multimodal, and sensor-based datasets. From object identification and keypoint labeling to action recognition and synchronized sensor annotation, our approach focuses on building reliable datasets for advanced robotic applications.
By combining structured annotation workflows with human-led quality assurance, Annotera helps prepare training data that supports complex manipulation scenarios, including coordinated two-arm operations.
Whether robotics teams are developing warehouse automation systems, industrial assembly robots, or next-generation embodied AI applications, high-quality data is essential for improving learning outcomes.
Conclusion
Bimanual manipulation represents an important step toward more capable and adaptable robotic systems. However, coordinating two arms requires robots to understand spatial relationships, synchronized movements, object interactions, and task dependencies.
Accurate robotic data annotation transforms raw demonstrations and multimodal sensor recordings into structured learning resources. It enables better grasping, coordinated movement, action recognition, and error correction.
As Physical AI continues to evolve, investing in high-quality datasets and reliable annotation processes will be essential for developing robots capable of performing increasingly sophisticated real-world tasks.
Ready to strengthen your robotics training datasets? Partner with Annotera for scalable, quality-driven robotic data annotation services that help advance intelligent manipulation and next-generation Physical AI systems.

 Arabic
 French
 Spanish
 Portuguese
 Deutsch
 Turkish
 Dutch
 Italiano
 Russian
 Romaian
 Portuguese (Brazil)
 Greek